GRADE 9 · MECHANICAL OSCILLATIONS
Harmonic, damped and forced oscillations
Harmonic law, energy loss and resonance.
Read the full lesson theory here without an account. In the interactive lesson, the same theory is presented as cards, followed by questions with feedback and practice problems. Your progress is saved.
Understanding step by step
Small pushes can build a large swing, while a badly timed push can slow it down. How does the rhythm of the drive change energy transfer, and why do real oscillations weaken without further pushes?
Ideal repetition
An ideal mass on a spring slows smoothly near the extremes and crosses the middle quickly. A sine or cosine describes this motion. Oscillations with constant amplitude and frequency whose displacement follows this law are called harmonic. Ideal springs and small-angle pendulums behave approximately this way when losses are negligible. Periodic motion does not always have this shape.
Position within a cycle
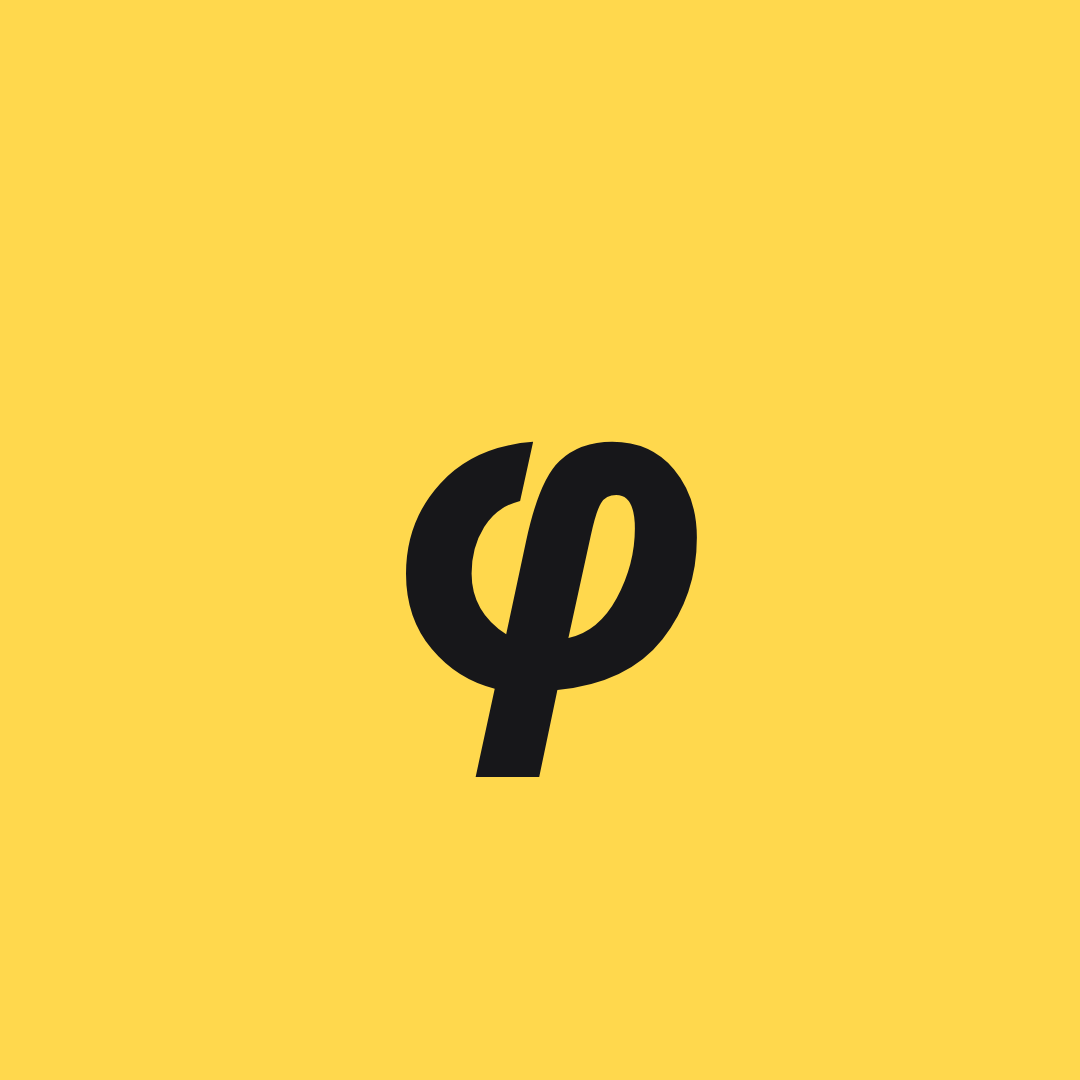
Two identical pendulums may share a period while one is on the right and the other on the left. Predicting position also requires phase φ, the stage within the cycle. Phase is measured in radians; one full cycle changes it by 2π. It describes both displacement and motion direction within the cycle. Adding 2π repeats the state, like a clock hand after a full turn.
How fast does phase change?
Phase increases by 2π during period T. Its rate of change is therefore ω = 2π/T = 2πν, the angular frequency in rad/s. Frequency ν counts cycles per second; ω counts phase radians per second. Doubling ν doubles ω and halves T. Their numerical values differ by 2π, so never substitute hertz for radians per second without checking which symbol a formula uses.
Write the motion law
Combine the description: x = A cos(ωt + φ₀). Cosine repeats between −1 and +1, and A scales this to displacements from −A to +A in metres. ω sets the repetition rate, t is in seconds and φ₀ sets the initial state. The current phase is ωt + φ₀, not φ₀ alone. Increasing A stretches the graph vertically; increasing ω compresses it in time.
Cosine describes the state
Check a familiar release: pull the mass to +A and let go without a push. Then φ₀ = 0 because cos 0 = 1. After T/4, phase is π/2 and x = 0; after T/2, phase is π and x = −A. The same x = 0 occurs twice per cycle with opposite motion directions. Choose initial phase from the full starting state, not just a coordinate value.
Why does amplitude decrease?
Real swings eventually stop without deliberate braking. Resistance does negative work, turning some mechanical energy into internal energy of objects and air. Free oscillations started by one displacement or push become damped: amplitude decreases. Removing losses in thought would stop this decrease. A formula with one constant A cannot exactly describe the whole damped motion.
An external rhythm
To keep a swing moving, supply energy periodically. This produces forced oscillations. Natural frequency characterises the system's free motion, while the source chooses the driving frequency. For a linear system driven sinusoidally, once the initial transient oscillations decay, steady motion has the force's frequency. The two frequencies can differ, and the response depends on how close they are.
Resonant response
Try pushing a swing at different rhythms. With weak losses, amplitude becomes especially large when the driving frequency is close to the natural frequency: energy transfer is efficient from cycle to cycle. This enhanced response is resonance. Frequencies do not create energy; the person pushing does work. An ideal lossless model permits growth, but in a real system growth changes the balance of energy supplied and lost.
Losses limit growth
Why can a real swing not reach infinite amplitude? As motion grows, friction and resistance limit the response, and the linear model may cease to apply. A damper dissipates mechanical energy and reduces resonant vibration in machines. In a musical instrument, enhanced response in a useful frequency range is desirable. The same mechanism has different consequences depending on system parameters, driving frequency and losses.
Coordinate after half a period
A mass oscillates according to x = 0,04 cos(πt), with x in metres and t in seconds. Find amplitude, period and x after 1 s.
Let's look at an example · 1
Compare x = 0,04 cos(πt) with x = A cos(ωt + φ₀). The cosine coefficient gives A = 0,04 м = 4 см; ω = π рад/с, φ₀ = 0.
Let's look at an example · 2
A full-cycle phase increase of 2π takes T = 2π/ω = 2 с. Thus 1 s is half a period.
Let's look at an example · 3
x(1) = 0,04 cos π = −0,04 м = −4 см.
Let's look at an example · 4
The mass starts at the right extreme +A and reaches the left extreme −A after half a cycle. This agrees with the calculated coordinate, whose magnitude does not exceed amplitude.
Check the result
A = 4 см, T = 2 с, x(1 с) = −4 см. In one second the mass travels from the positive extreme to the opposite extreme.
Key point · 1
The harmonic law separates amplitude A, rate ω and initial state φ₀; current phase changes with time.
Key point · 2
Damping transfers mechanical energy to other forms; maintaining motion requires an energy supply.
Key point · 3
Resonance enhances the response to an external force at a suitable frequency; the energy source remains external.
What comes next
When oscillations are passed to neighbours, a wave forms.
Basic Concepts
Damped and forced oscillations
Damped oscillations decrease in amplitude because of resistance; forced oscillations are maintained by an external periodic force.
After the transient dies away, the driven system oscillates at the driving frequency.
Harmonic oscillations
Oscillations whose coordinate follows a sine or cosine law at constant frequency.
Phase specifies the oscillator's state at a chosen instant and allows different oscillations to be compared.
Resonance
A strong increase in forced-oscillation amplitude when driving and natural frequencies are close.
Resonance is useful in musical instruments and radio technology but can endanger bridges and machines without damping.
Physical quantities
Phase
\varphiφ is the current phase; φ₀ is initial phase at t = 0. In harmonic motion, φ = ωt + φ₀; phase gives the stage of oscillation within a period.
Unit: radian · \mathrm{рад}
Angular frequency
\omegaThe rate at which the phase of harmonic oscillation changes.
Unit: radians per second · \frac{\mathrm{рад}}{\mathrm{с}}
Lesson formulas
Harmonic law
x=A\cos(\omega t+\varphi_0)Displacement from equilibrium equals amplitude times the cosine of current phase ωt + φ₀; φ₀ is initial phase.
Conditions: Harmonic oscillations with constant amplitude and frequency, with coordinate zero at equilibrium.
Test the relationship
Make a prediction first. The button changes the stated quantity; then compare the result and explore other values.
Resonance and damping
A = F₀/√[(k − mω²)² + b²ω²]; ω = 2πν
Linear oscillator: m = 1 kg, k = 4π² N/m, F₀ = 1 N, resistive force −bv. Only steady-state response is shown, without the initial transient.
At ν = 1 Hz, damping increases from 0.5 to 1 kg/s. How will the steady-state amplitude change?
Initial values
Calculated result
- A
- 0.3183 м
Explaining the result
Damping limits amplitude and broadens the peak. With damping, the peak lies slightly below the natural frequency of 1 Hz; resonance does not mean infinite amplitude.
Related formulas
The same formulas in the reference, with symbols and units.
Problems on this topic
Statements, answer options and the walkthrough.